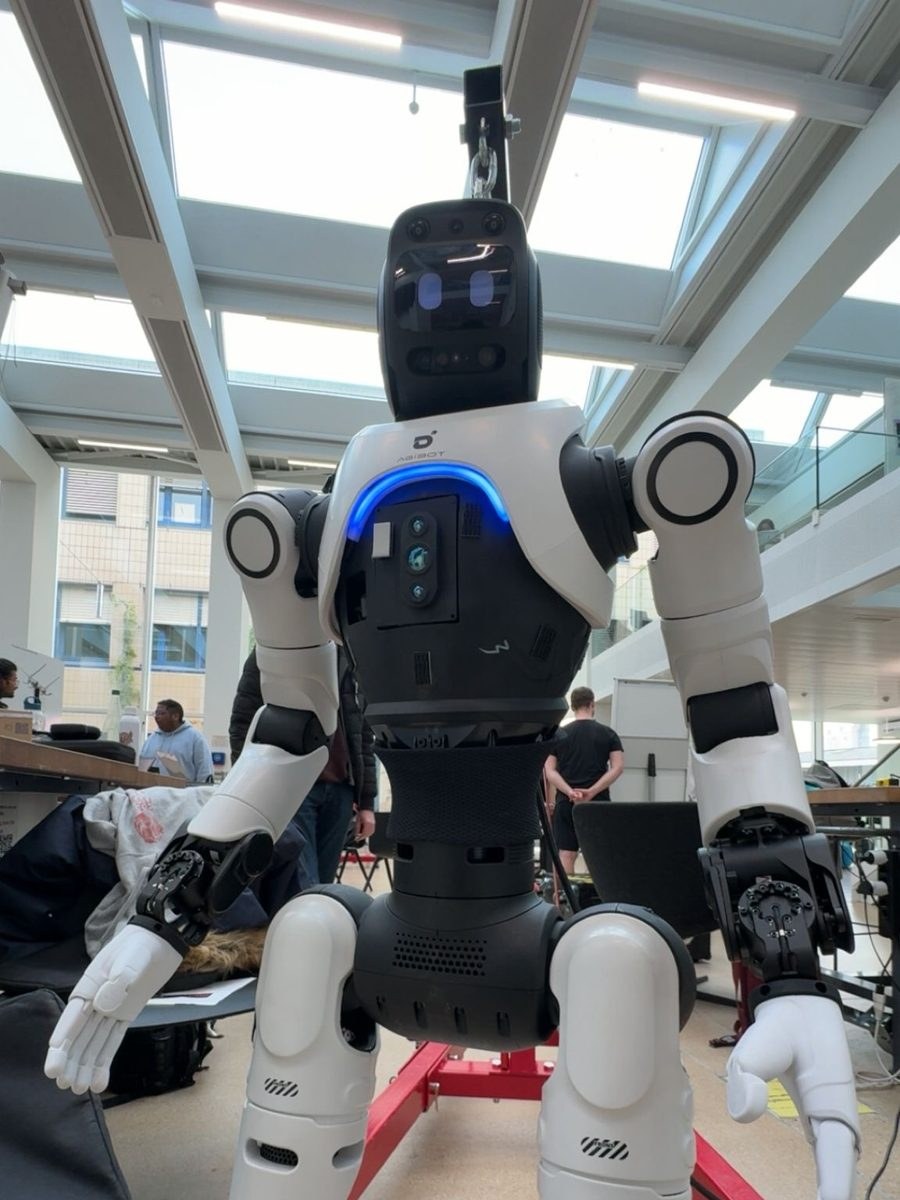
AgiBot X2 Humanoid for Elderly Care
Whole-body motion and person-tracking behaviours on the AgiBot X2 humanoid, enabling autonomous following and physical assistance for standing up.
Problem and motivation
Elderly-care assistance: a humanoid that can follow a person and help them stand up. The AgiBot X2’s software stack was early-stage, with limited public documentation.
System
The code is split into two ROS 2 packages:
- Perception (
robot_vision). Real-time stereo person detection with YOLOv8 and per-person stereo depth, publishing the target person’s position. - Motion (
robot_motion). Head tracking toward the target, a locomotion supervisor that walks toward the person and stops at a set distance, and an arm pose triggered on arrival.
Challenges
Integrating perception with whole-body control on an early-stage stack meant troubleshooting the robot software and iterating on behaviours directly on the physical humanoid.