Projects
Robot learning, control and engineering projects. Each card links to a detailed write-up.
Robot learning & control
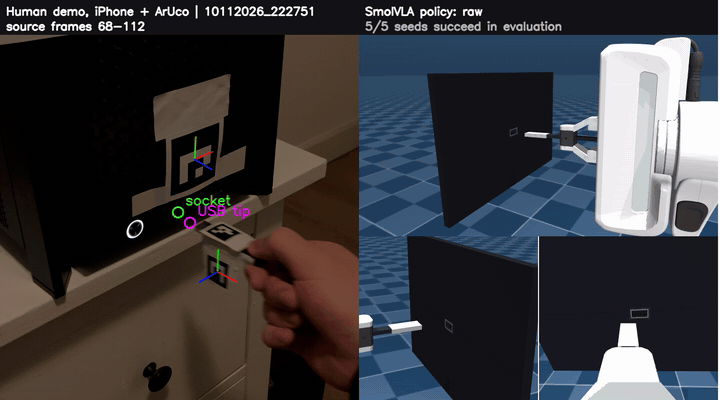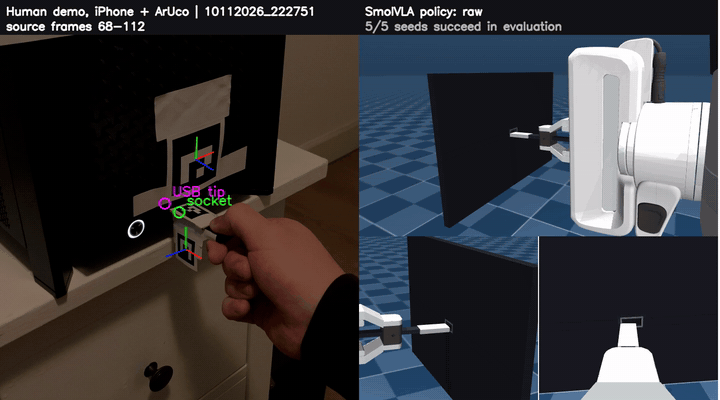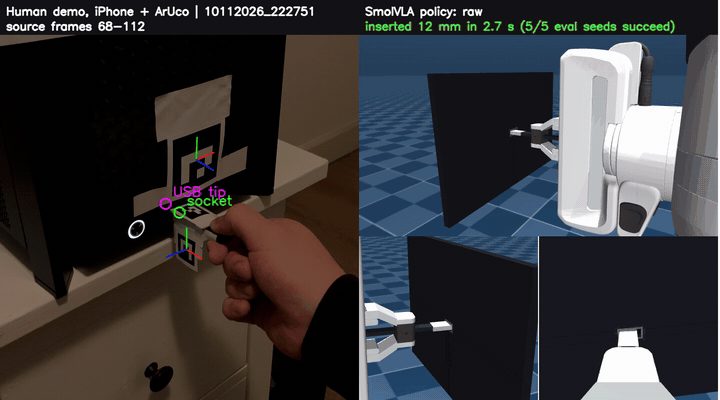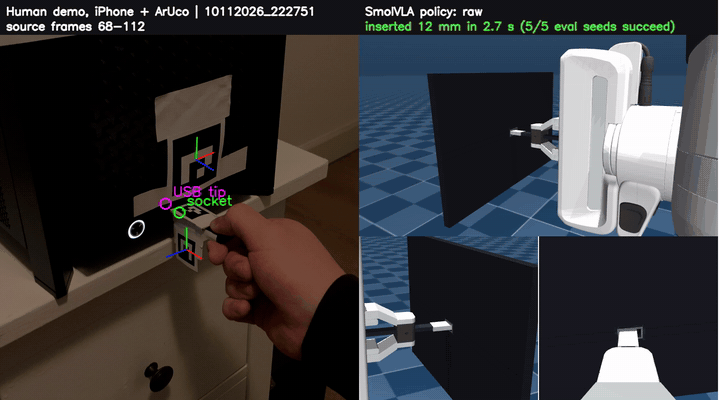
MimicVLA: Learning Insertion from Phone Videos
Teaching a simulated Franka Panda to plug in a USB stick from 134 iPhone videos of my own hand, by retargeting the motion in MuJoCo and fine-tuning the SmolVLA vision-language-action model.
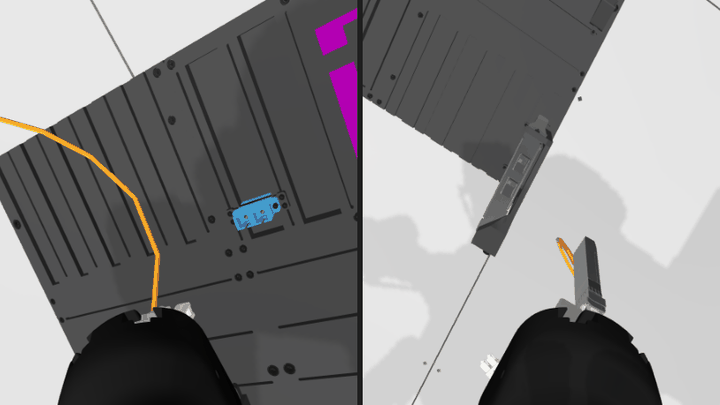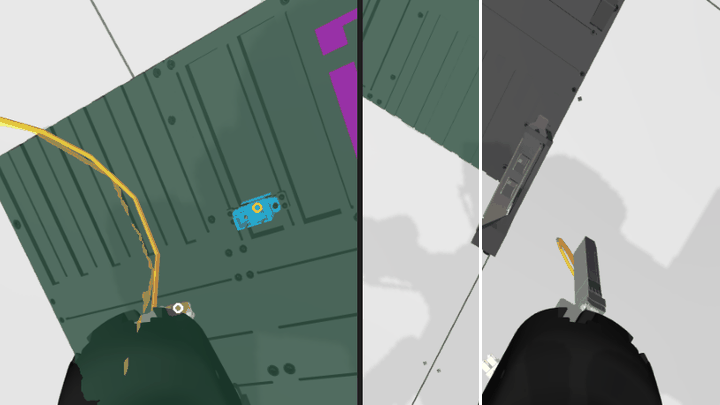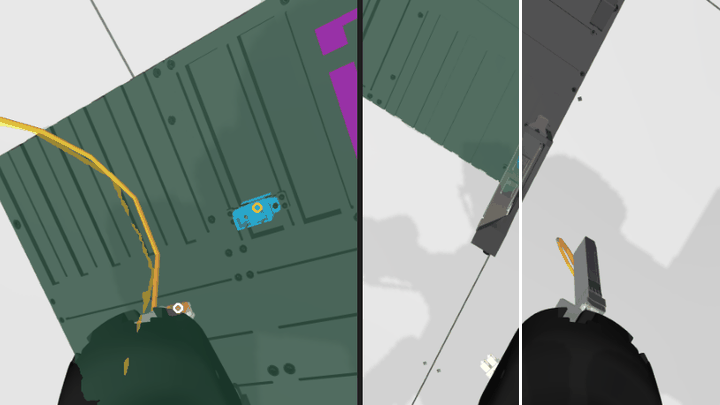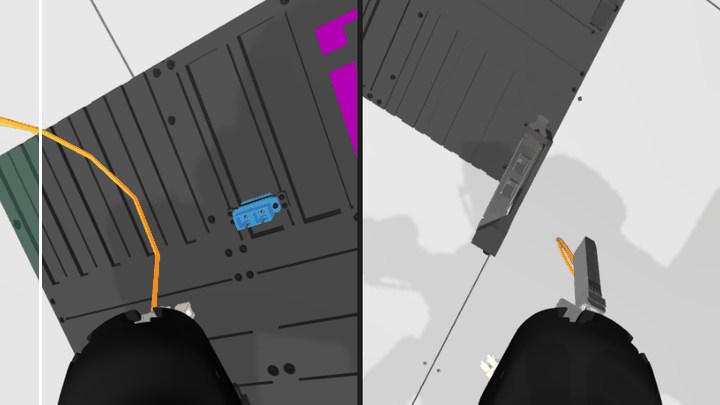
Multi-Camera Perception for Robotic Cable Insertion
Trained the perception model for our team's entry to the Intrinsic AI for Industry Challenge: segmentation and keypoints of cables, plugs and ports from three robot cameras, reaching 88.5% mIoU on held-out views.
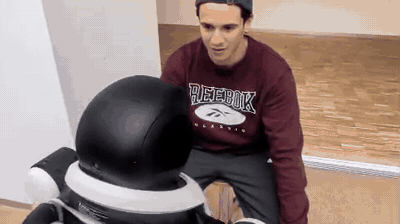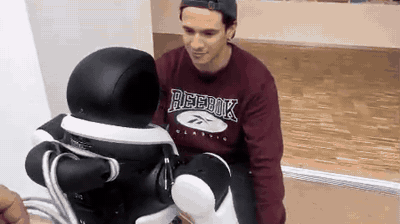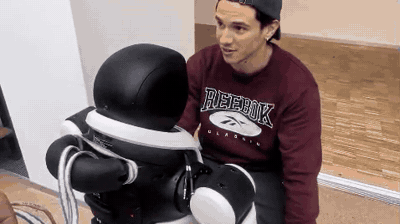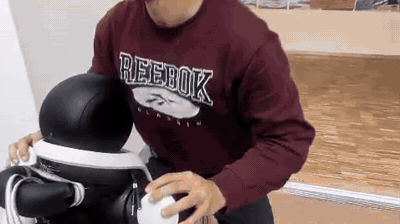
AgiBot X2 Humanoid for Elderly Care
Whole-body motion and person-tracking behaviours on the AgiBot X2 humanoid, enabling autonomous following and physical assistance for standing up.
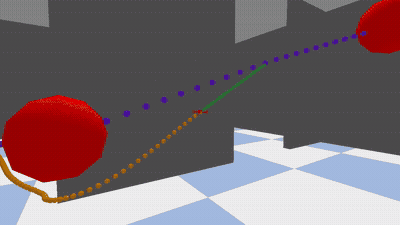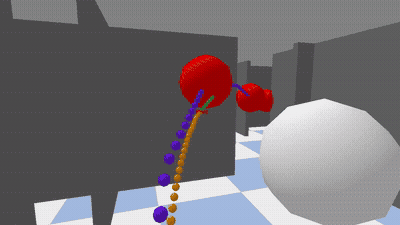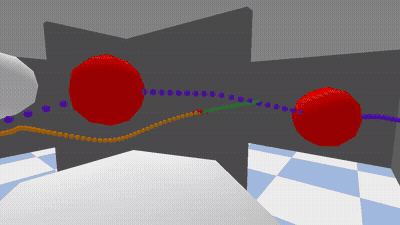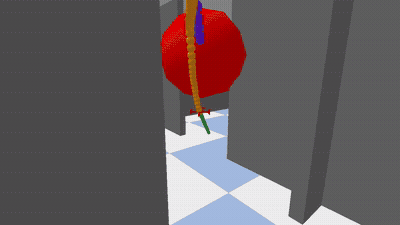
Autonomous Quadrotor Navigation with MPC
An RRT* global planner and a constrained MPC that tracks its path and avoids obstacles the global plan did not know about, on a simulated quadrotor in PyBullet.
Deep Reinforcement Learning Library
A modular deep RL library written from scratch in PyTorch, with PPO, SAC, DQN and actor–critic methods validated on discrete and continuous-control tasks.
Engineering
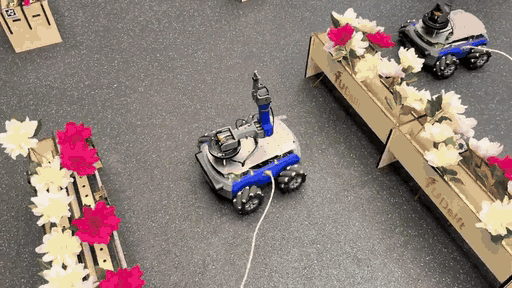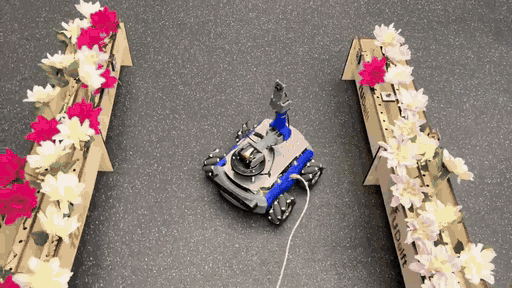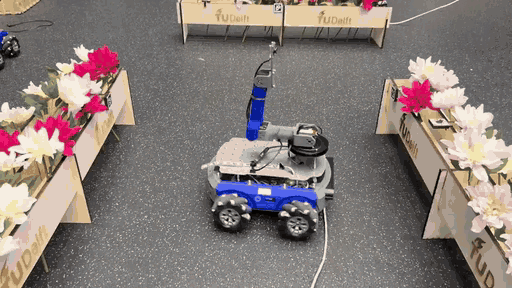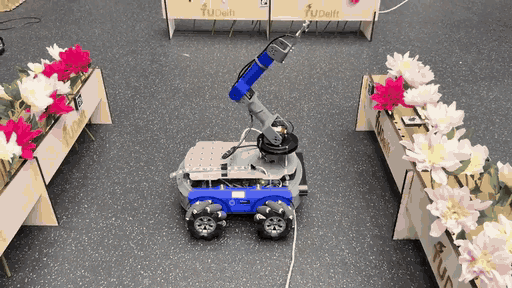
Autonomous Greenhouse Inspection Robot
A mobile manipulator that maps a greenhouse, drives between flower beds and scans each bed with an arm-mounted camera, reporting where every flower and pest is.
Real-Time Control Testbed for 6G Networks
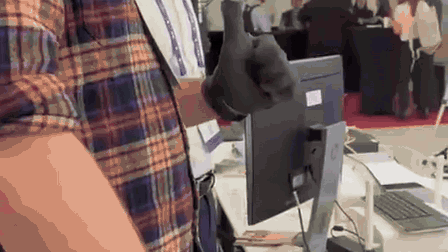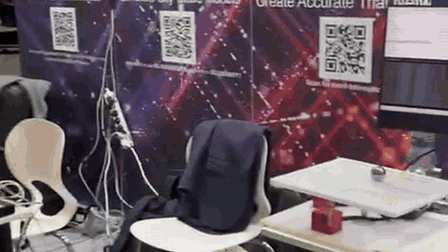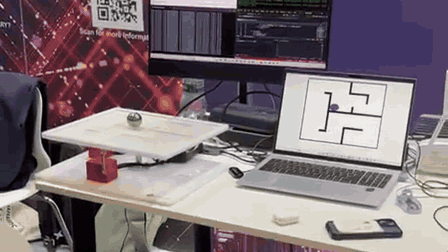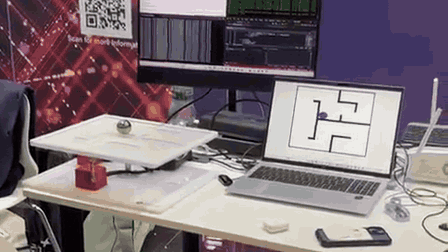
A hand-teleoperated ball-balancing table for the 6G-SANDBOX, used to show how network latency and where the computation runs affect a control task that needs fine precision.
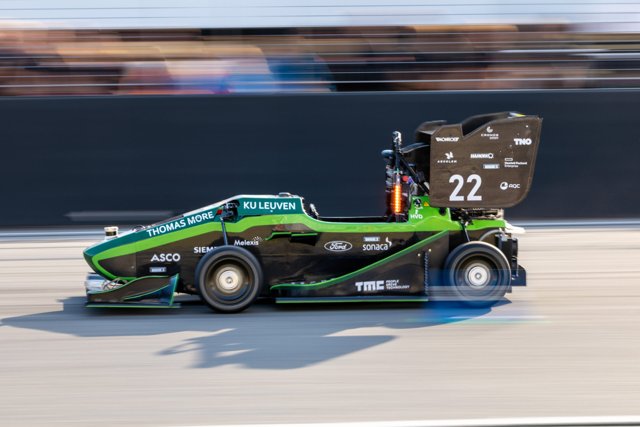
Torque Vectoring for a Formula Student Car
Torque-vectoring control algorithms for an electric Formula Student race car, from vehicle-dynamics models in MATLAB to C++ running on the car.
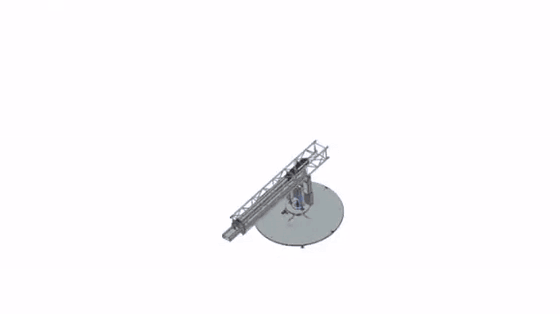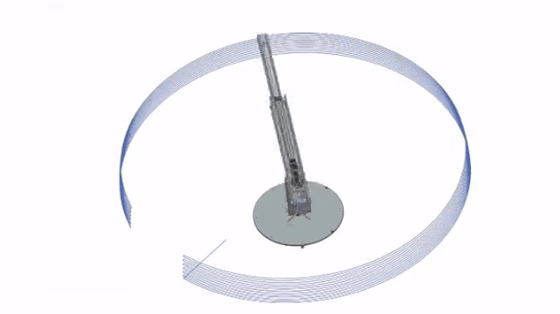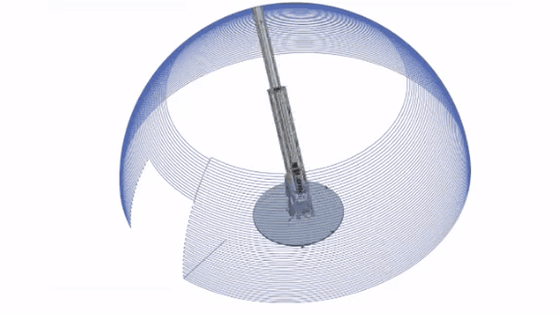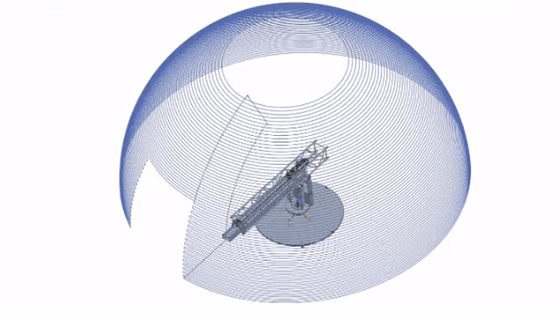
Digital Twin of a 3D-Printing Construction Robot
A full-scale machine that 3D-prints a dome-shaped house from sludge, for rapid housing after natural disasters: mechanical design, electrical design and a digital twin in Siemens NX.