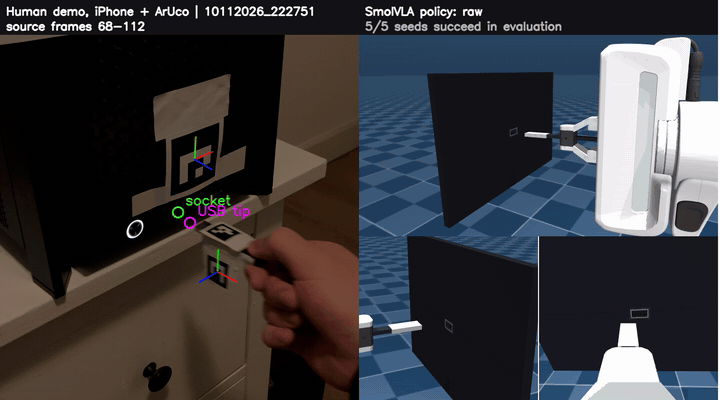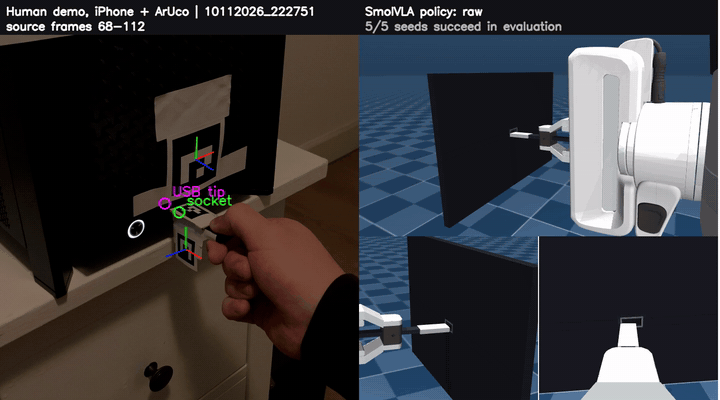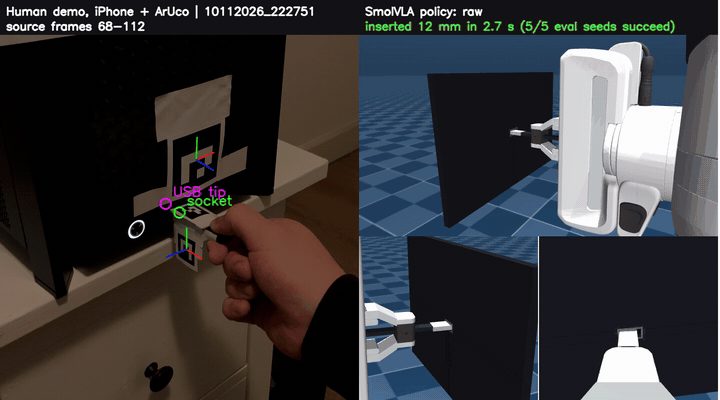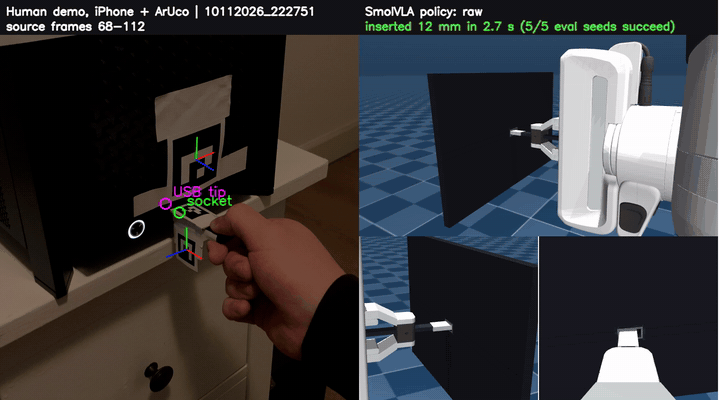
MimicVLA: Learning Insertion from Phone Videos
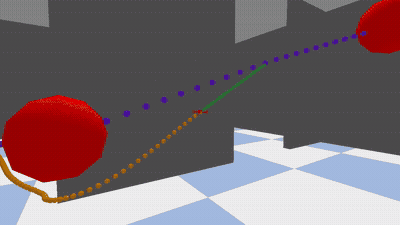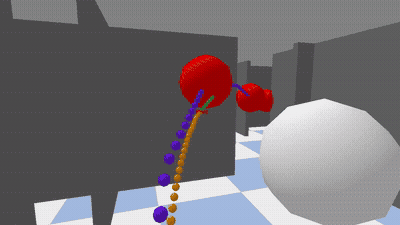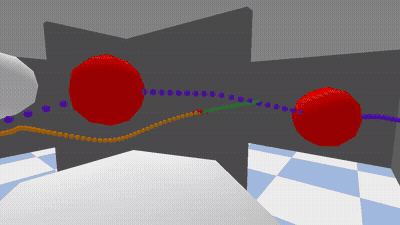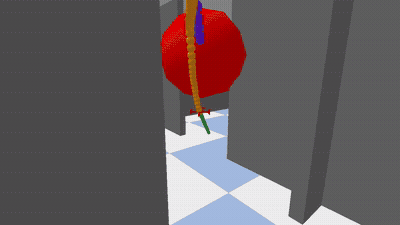
Teaching a simulated Franka Panda to plug in a USB stick from 134 iPhone videos of my own hand, by retargeting the motion in MuJoCo and fine-tuning the SmolVLA vision-language-action model.
MSc Robotics, TU Delft · Student Researcher, AMR Lab
I am an MSc Robotics student at TU Delft and a student researcher at the AMR Lab, supervised by Sihao Sun and Javier Alonso-Mora. My thesis asks whether embodiment-agnostic world models can plan for embodiment-specific robots, using an aerial manipulator performing contact-rich tasks as the case study.
I work on robot learning: deep reinforcement learning, imitation learning and learned world models, with a focus on manipulation skills that transfer from simulation to real robots. I came to research from engineering. I studied Electromechanical Engineering at KU Leuven, where I graduated first of 360, and during and after that degree I built a real-time control testbed at Keysight Technologies and torque-vectoring controllers at Formula Electric Belgium.
I am looking for research roles in robot learning, reinforcement learning and world models.
Can world models trained independently of a robot's embodiment be used to plan for a specific robot with very different dynamics? Case study: contact-rich manipulation with an aerial manipulator.
Research direction →Teaching a simulated Franka Panda to plug in a USB stick from 134 iPhone videos of my own hand, by retargeting the motion in MuJoCo and fine-tuning the SmolVLA vision-language-action model.
Trained the perception model for our team's entry to the Intrinsic AI for Industry Challenge: segmentation and keypoints of cables, plugs and ports from three robot cameras, reaching 88.5% mIoU on held-out views.
Whole-body motion and person-tracking behaviours on the AgiBot X2 humanoid, enabling autonomous following and physical assistance for standing up.
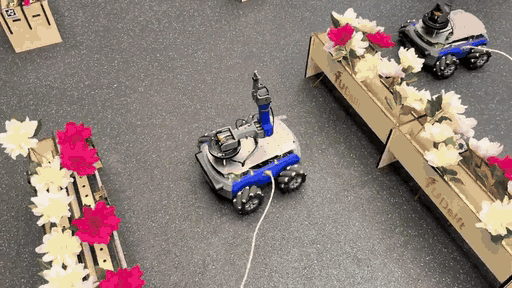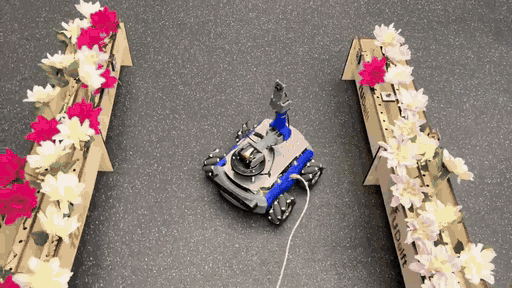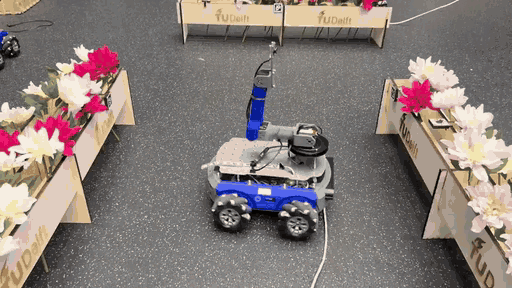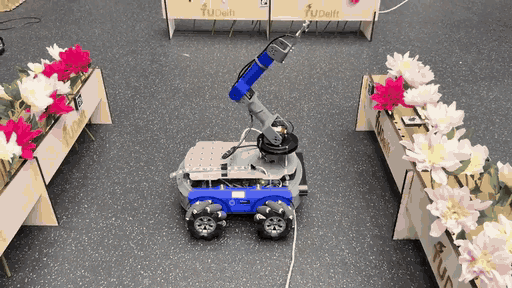
A mobile manipulator that maps a greenhouse, drives between flower beds and scans each bed with an arm-mounted camera, reporting where every flower and pest is.
An RRT* global planner and a constrained MPC that tracks its path and avoids obstacles the global plan did not know about, on a simulated quadrotor in PyBullet.